VEX V5 Robotics · Team 3142C
A robot has to work outside the workshop.
I captain 3142C at Paideia in Atlanta. We build and program a machine together, then find out what holds up when it meets another robot, a clock, and an actual field.
The record
Two seasons, two different tests.
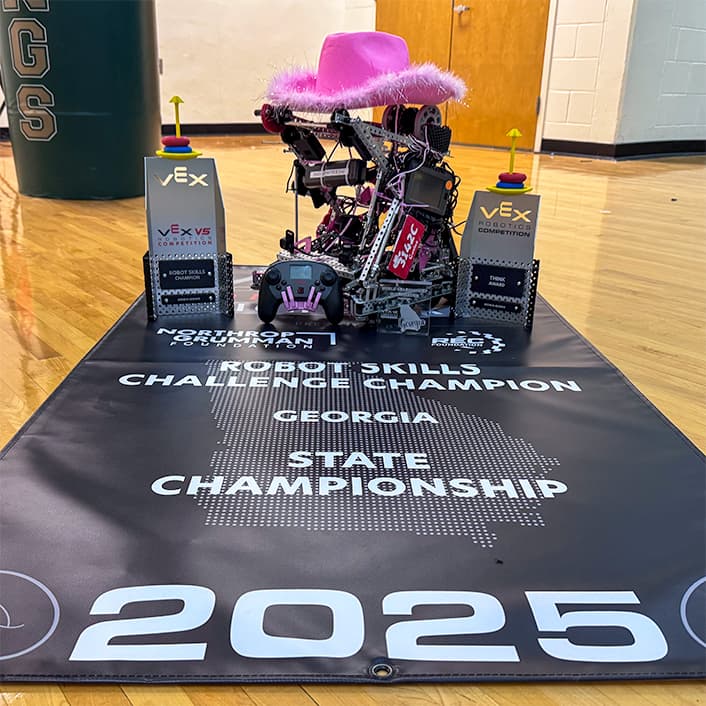
In 2025, the team won Georgia State's Robot Skills Challenge Champion and Think Award honors. VEX Robotics profiled the team and photographed the robot above.
Our team reached the World Championship three times during my captaincy. In 2026, we made the playoffs in our division at Worlds in St. Louis. Our team also received the Judges Award at Carolina Countdown. These are team results, not individual awards.
Failure is data
The field changed what we trusted.
The matchloader blocked a sensor. When that mechanism extends, it obscures the robot's front distance sensor. Our control code excludes that reading while the matchloader is out and restores it when the mechanism retracts. A sensor can be working perfectly and still be wrong for the robot's current shape.
Long routes exposed position drift. Wheel slip and contact made the odometry estimate less trustworthy over time. I worked on PALE to test wall- and GPS-based corrections, then kept continuous correction off in the last recorded skills route when the evidence was not strong enough to trust it. The one-shot localization step at the start remained.
That same field-side habit shaped Scoutly: a competition-day tool has to answer the next useful question quickly, and show when its data is stale.